
Adaptive Cruise Control


- Maintains safe following distance
- Automatically adjusts speed
- Enhances highway driving comfort

Automotive & Mobility
Software-defined vehicle engineering across ADAS, perception, controls, validation, safety and cybersecurity.
 Vehicle Tracking
Lane Detection
Radar Waves
Trajectory Planning
Pedestrian Detected
Software Defined
Vehicle
AI & Perception
Driven
Functionality safety
First
Cybersecure
By Design
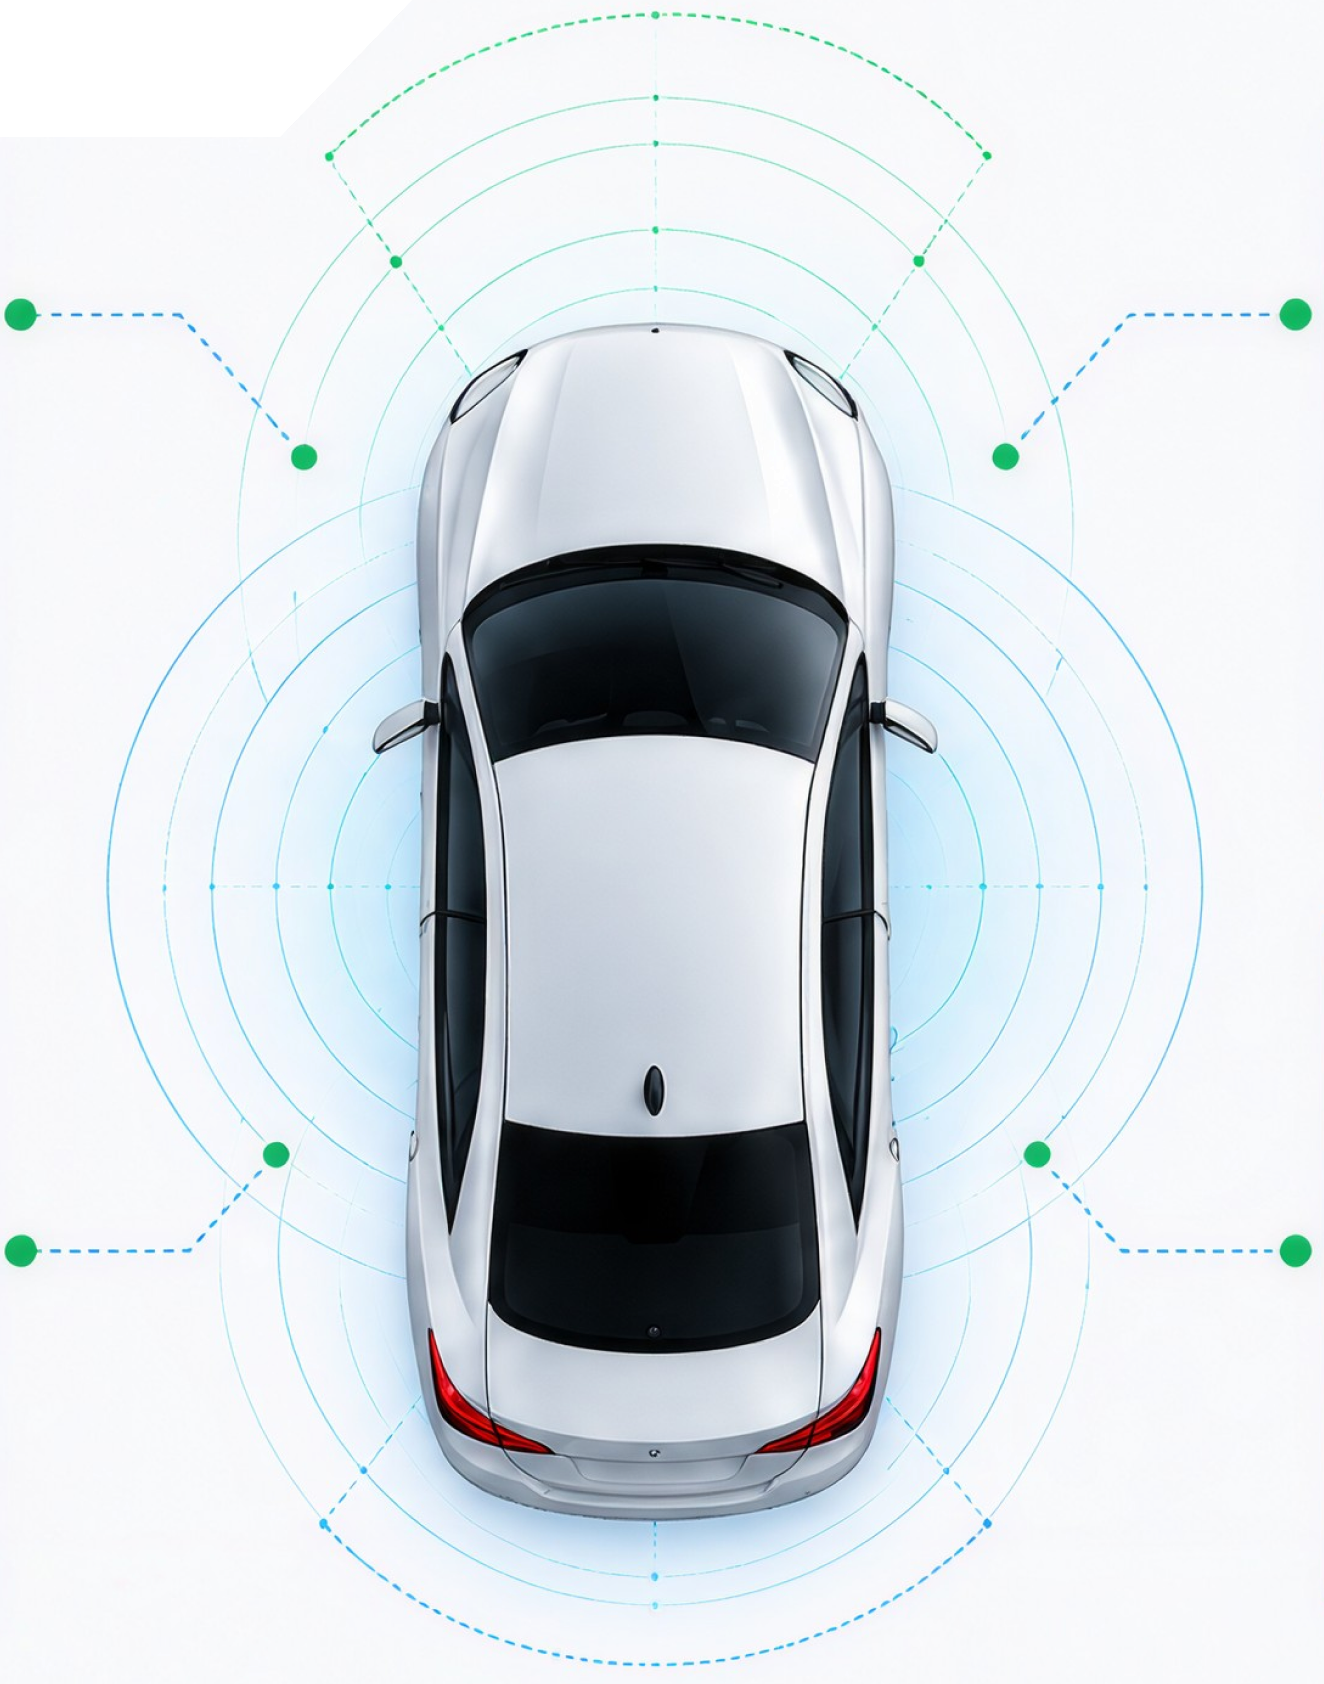
02 From Sensing to Safe Vehicle Decisions.
Our engineering approach transforms real-world sensor data into safe and intelligent vehicle behavior.

Radar • Camera • Ultrasonic • Lidar

Object Detection • Sensor Fusion • Localization

Planning • Decision Making • Prediction • Algorithms

Steering • Brake • Vehicle Control

SIL • HIL • VIL • Real-world
03 Software Defined
Building the intelligent foundation for next-generation mobility.
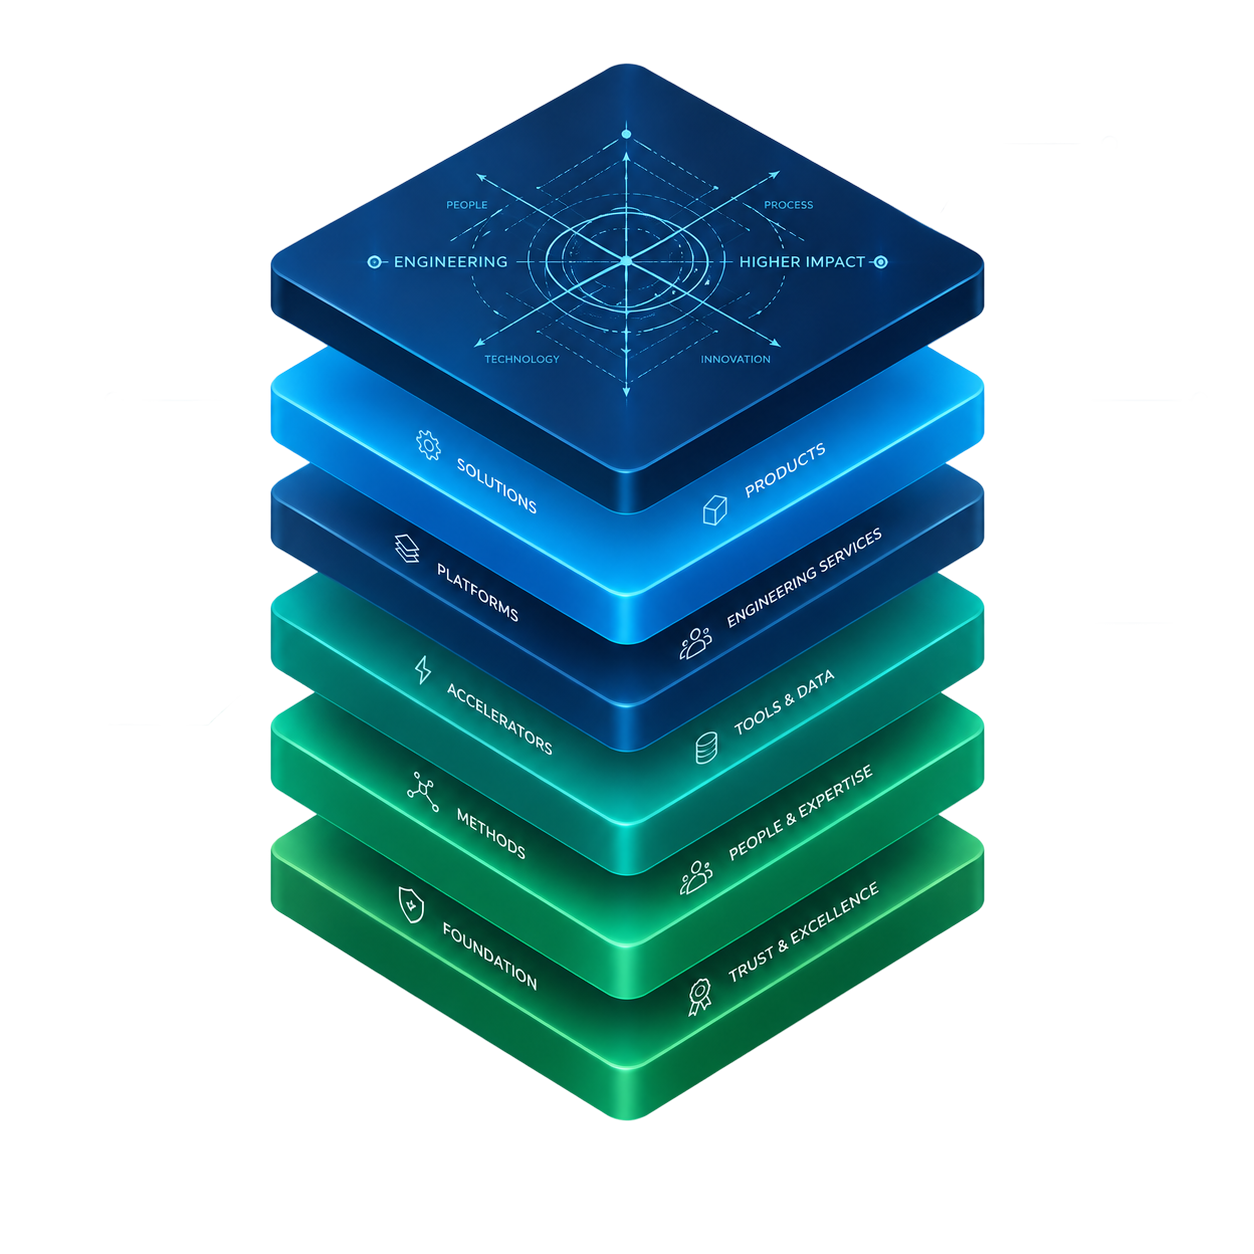


Connectivity • Infotainment • OTA • Fleet

ACC • AEB • LKA • TJP • Parking Assist

Object Detection • Tracking • Mapping • Prediction

Trajectory • Motion • Vehicle Dynamics

Fusion • Localization • State Estimation

Zonal • Domain • HPC • Compute

Ethernet • CAN • Flex Ray • AUTOSAR
03 ADAS
Advanced driver assistance features engineered for saftey and reliability.


04 Our Solutions
Intelligent, lean-angle aware distance keeping for safer two-wheeler mobility.
Inputs:
 Target Vehicle
 32 Meters
 77GHz RADAR + CAMERA
 SENSOR FUSION
 THROTTLE + BRAKE
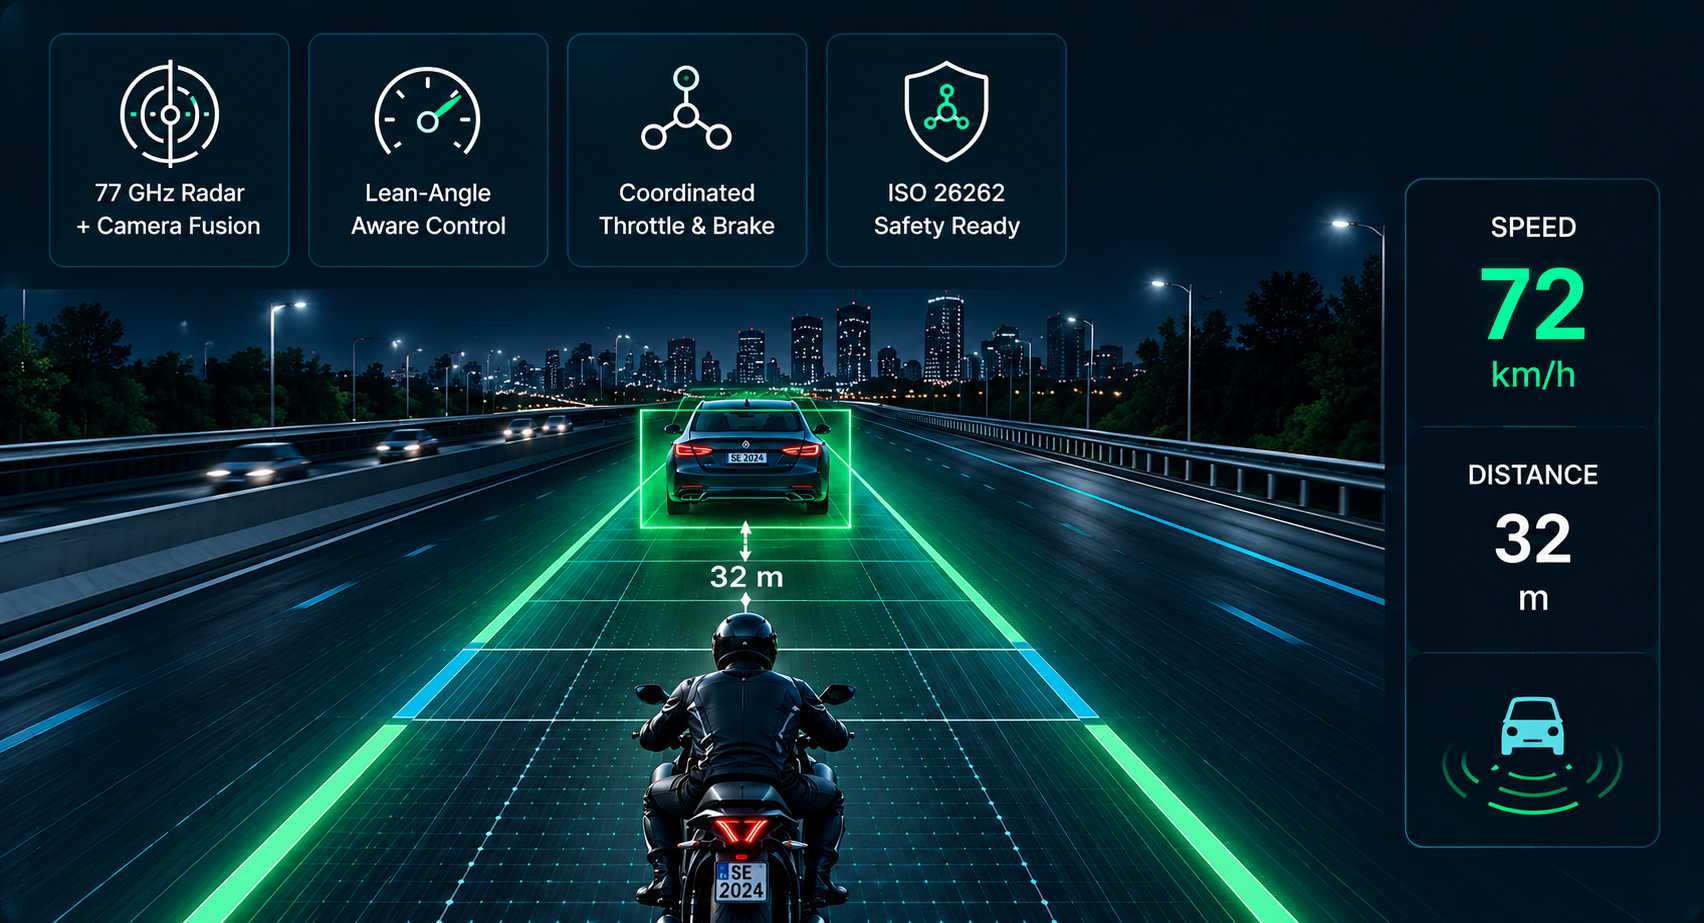
Advanced LiDAR validation across performance , accuracy and environmental conditions.
Inputs:
 Range
 Accuracy
 Object Detection
 Point Density
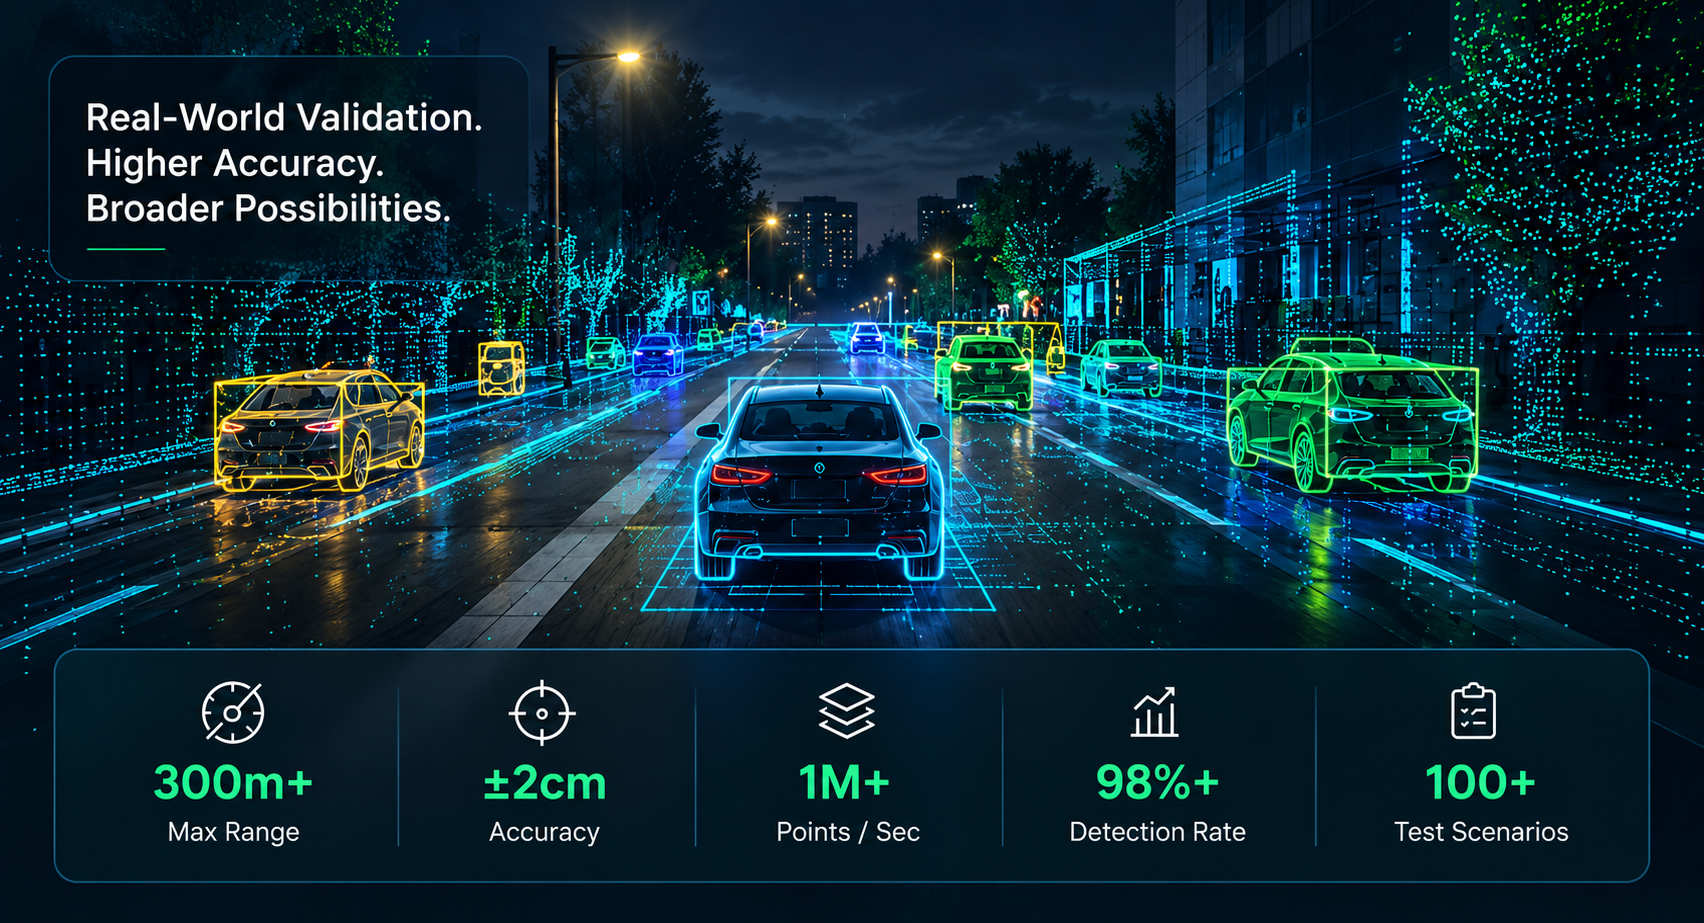
05 Workflow

Vehicle & Environment Modeling

Virtual Testing

Software-in-the-loop Validation

Hardware-in-the-loop Validation

Vehicle-in-the-loop Validation

Prototype Build & Integration

Data Collection & Analysis

Continuous Improvement
06 Ecosystem

Global Partnerships

Advanced Driver Assistance System

Software Defined Vehicles

Future Mobility Solution
Partner with SpeedEdge for mission-critical engineering, compliance and validation.
