
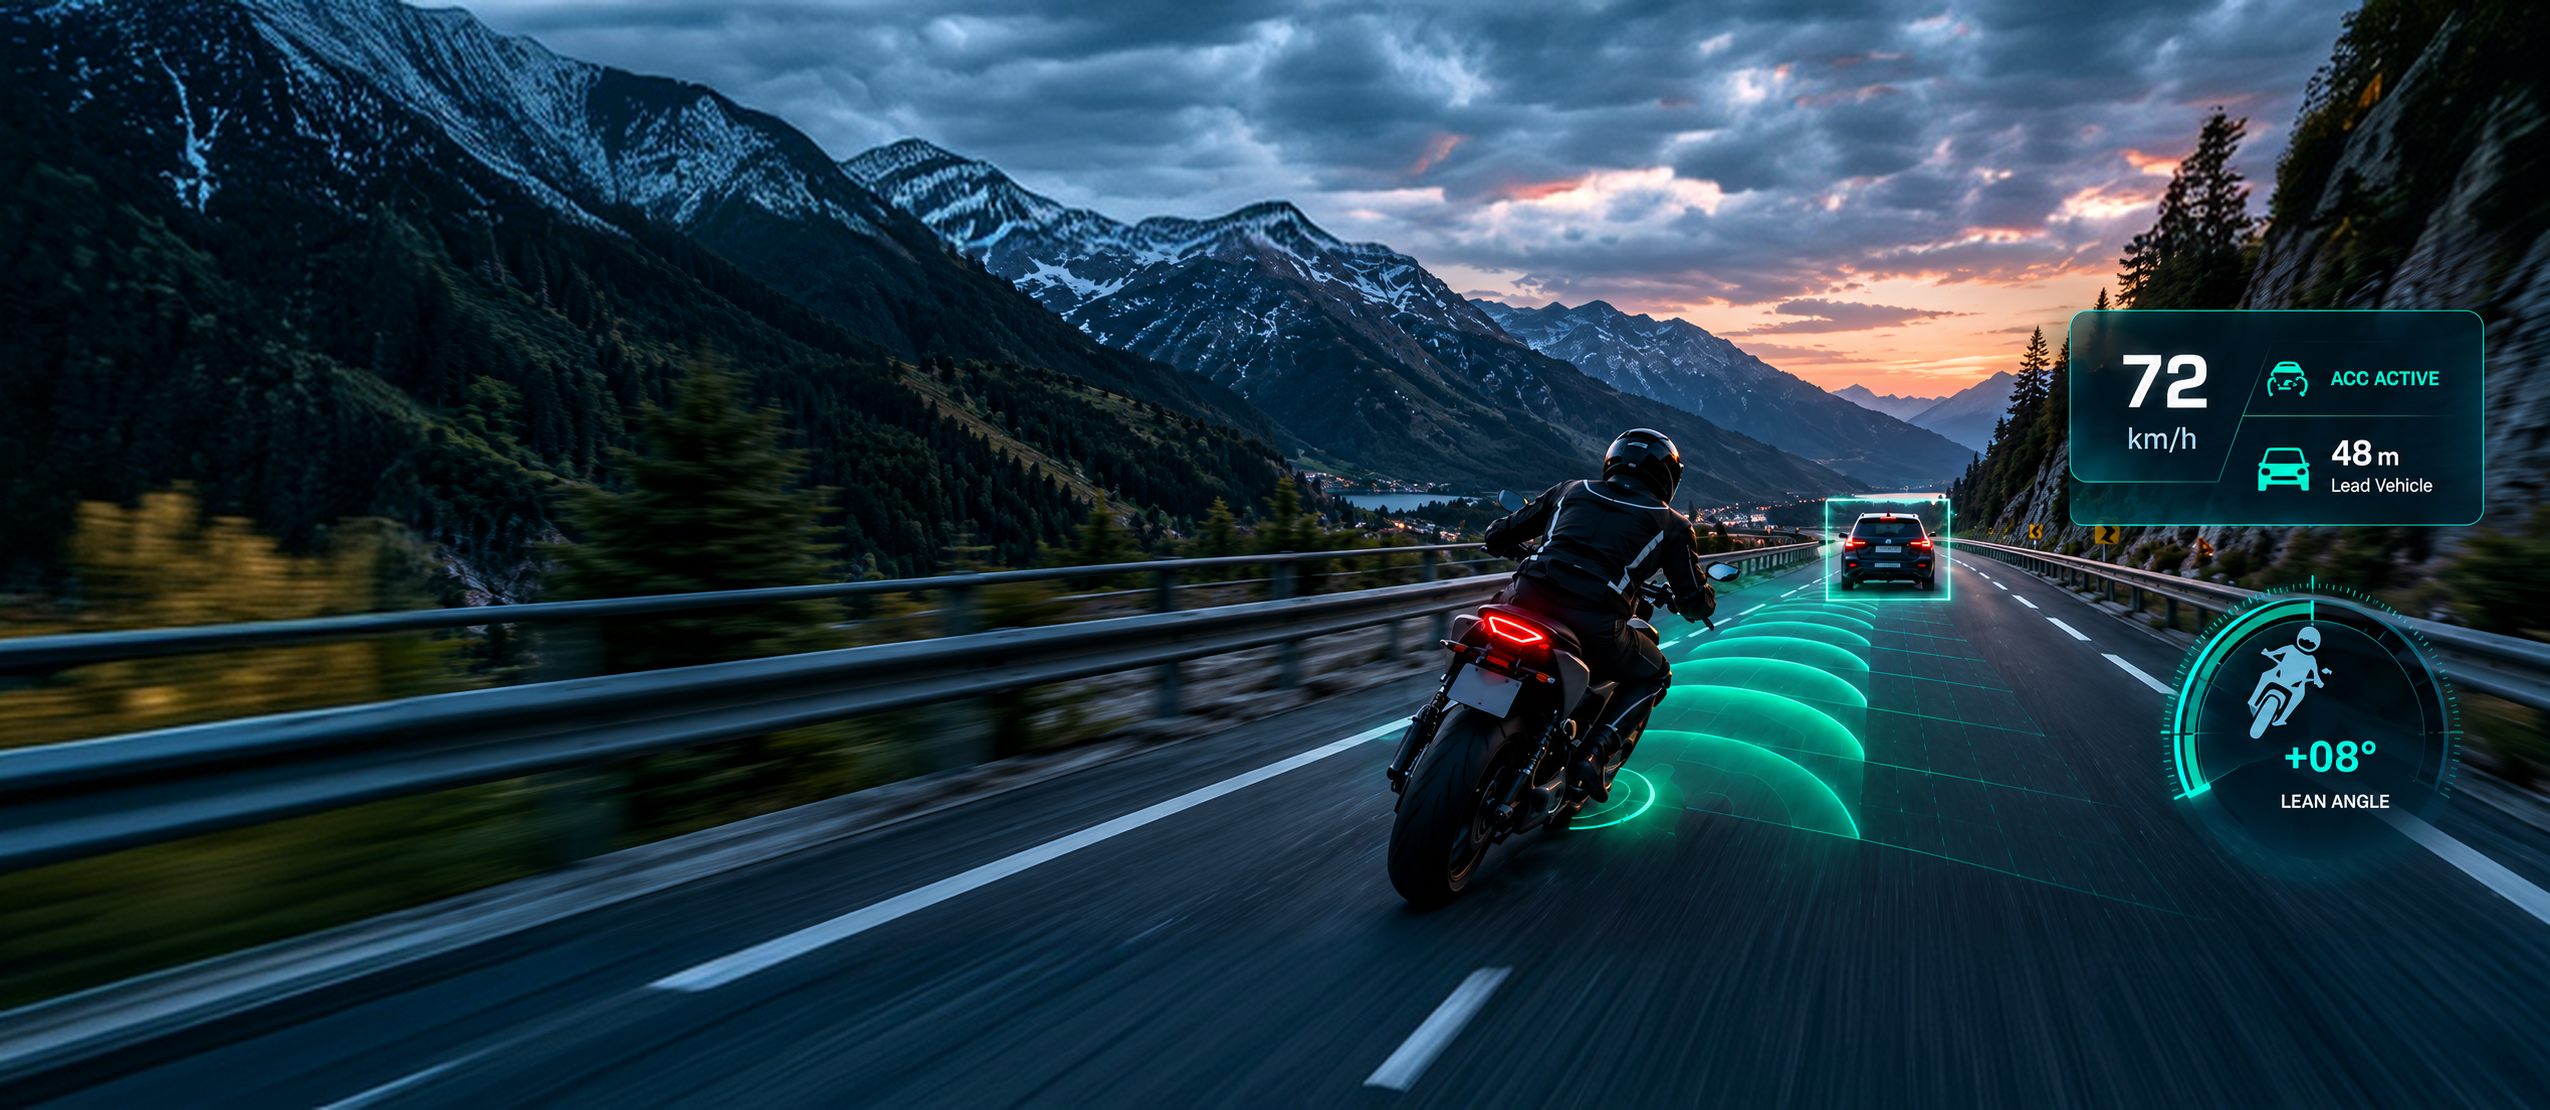
2-Wheeler ACC Product
Adaptive Cruise
Control
Rethought
for Two-Wheelers.
Radar-based Adaptive Cruise Control engineered for motorcycles — maintaining a safe, comfortable following distance while respecting the unique dynamics of two-wheelers.
02 Product intro
Safety and comfort.
Without losing control.
Two-wheelers introduce unique dynamics: lean angles, narrow vehicle footprint and rider-in-the-loop control. 2-Wheeler ACC adapts longitudinal assistance around these requirements, helping maintain a rider-selectable gap while coordinating acceleration and deceleration within two-wheeler stability limits.
-
 01

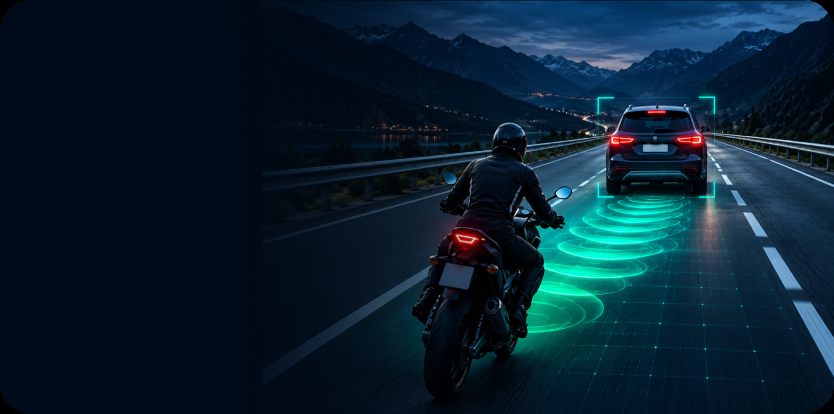
Adaptive Distance
KeepingAutomatically maintains a rider-selectable safe gap to the vehicle ahead.
-
 02
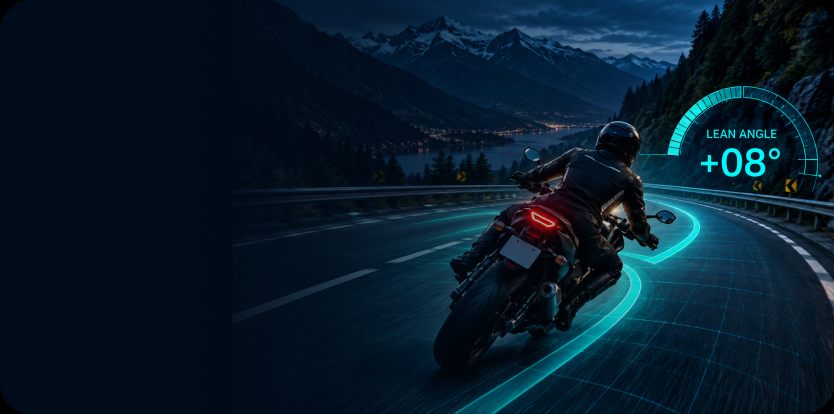
Lean-Angle
CompensationCorrects radar target association for roll angle so tracking remains reliable through curves.
-
 03
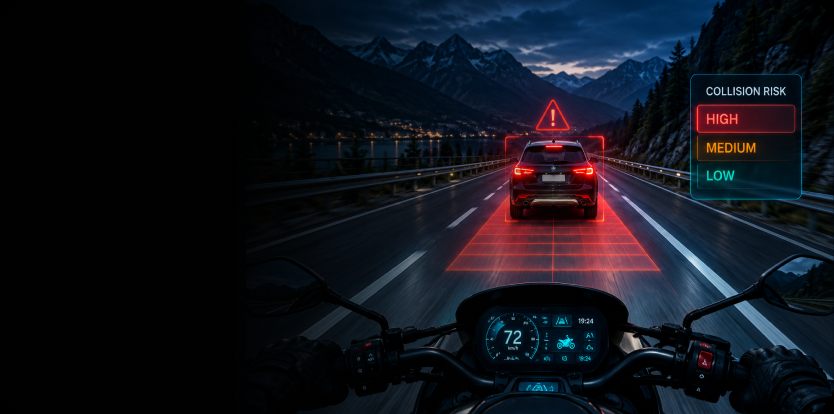
Forward Collision
WarningProvides escalating alerts when closing speed to a lead vehicle becomes unsafe.
-
 04
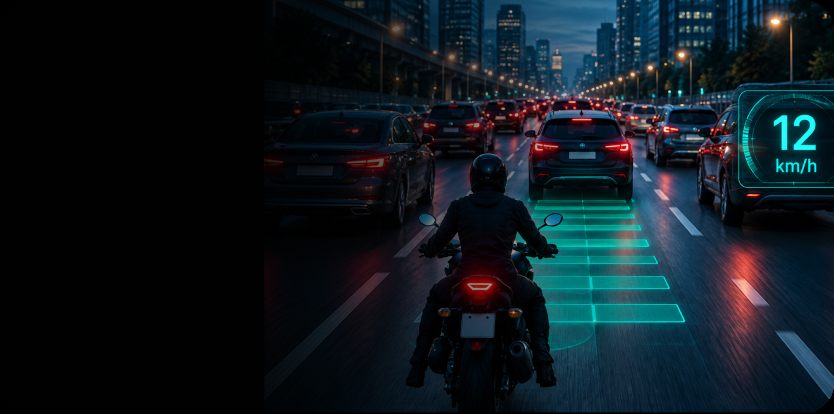
Low-Speed
FollowSupports comfortable stop-and-go following in dense highway and urban traffic.
-
 05
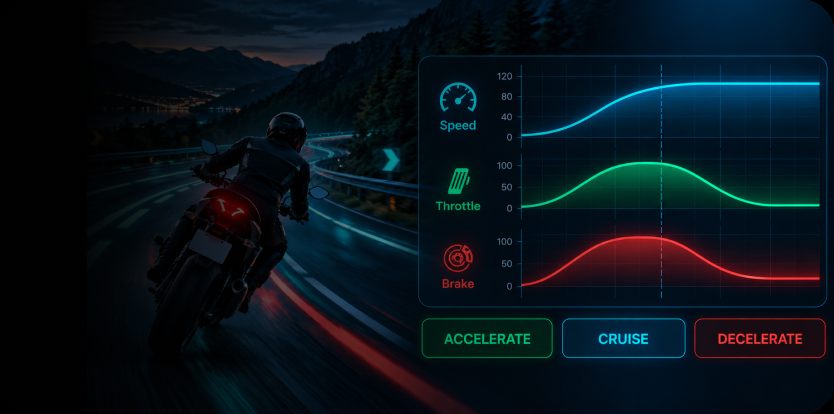
Throttle & Brake
BlendingProvides smooth acceleration and deceleration within two-wheeler stability limits.
-
 06
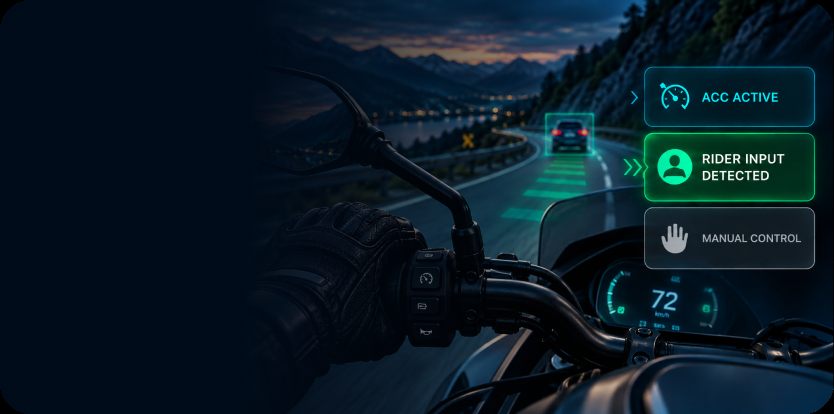
Rider-in-the-Loop
OverrideKeeps rider input as the priority, enabling an immediate and intuitive handover.
03 The 2-Wheeler ACC workflow
From Sensing to
Confident Rider Assistance.
-
01. Sense

Capture the environment and vehicle state.
-
02. Perceive

Identify and track vehicles ahead.
-
03. Decide

Determine the appropriate longitudinal response.
-
04. Control

Calculate acceleration and deceleration commands.
-
05. Actuate

Apply coordinated commands to the vehicle.
-
06. Handover

Maintain rider authority throughout the system.
04 Multi-source vehicle perception
One Control System.
Multiple Inputs.
2-Wheeler ACC combines complementary sensor and vehicle-state inputs to understand the road ahead and the motorcycle's dynamic state.
-
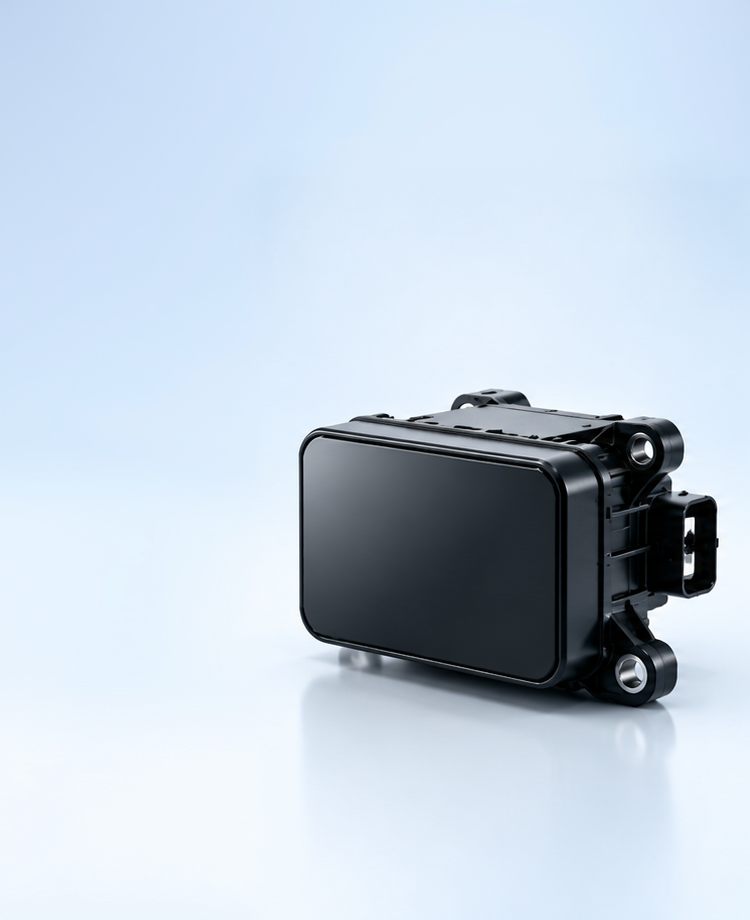
Radar
Long-range forward sensing for target detection and tracking.
-
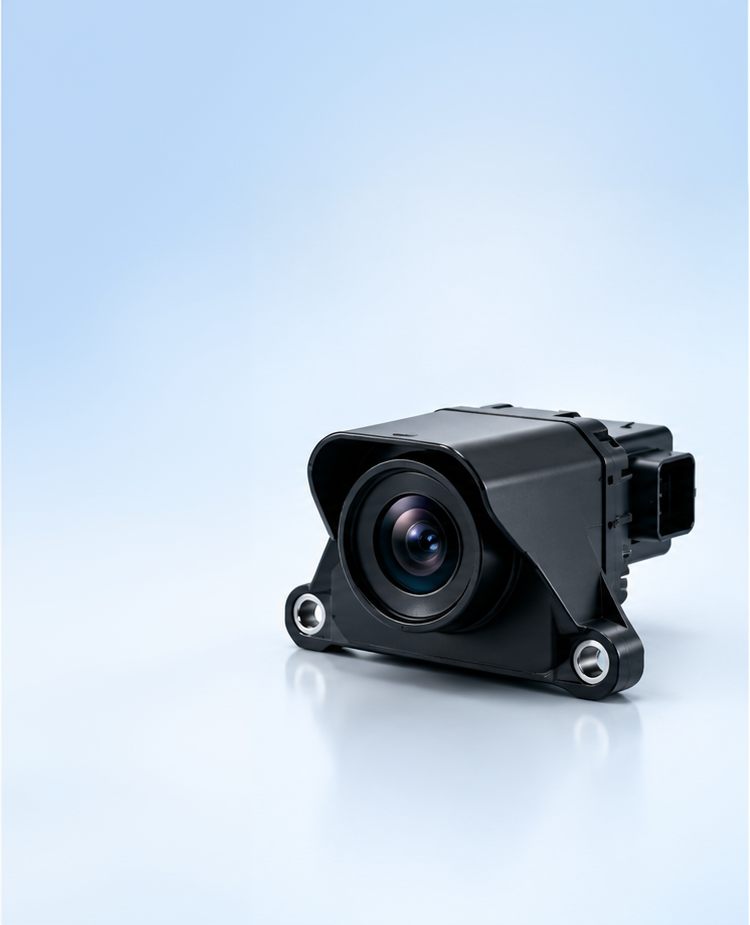
Camera
Visual perception supporting object detection and sensor fusion.
-
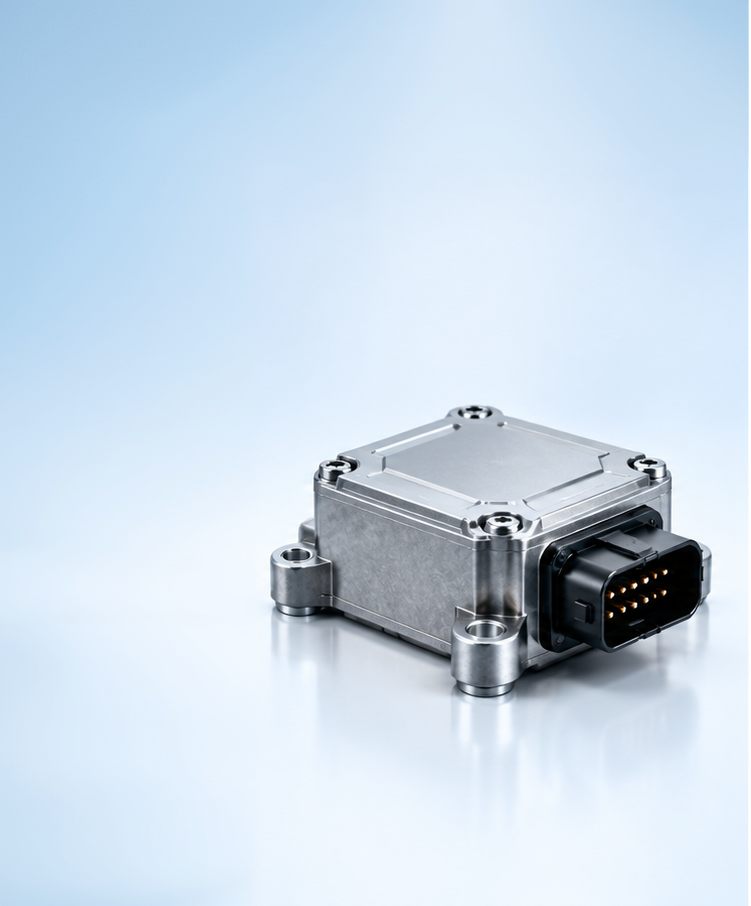
IMU
Provides vehicle motion and lean-angle information.
-
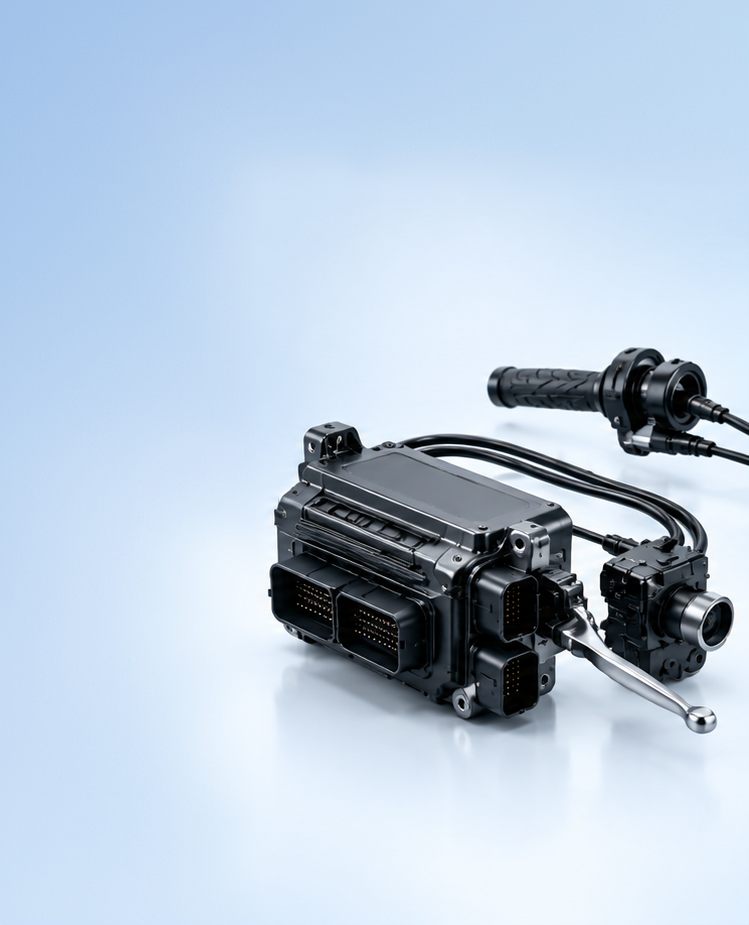
Vehicle Control
Provides the actuation interface for longitudinal assistance.
05 Lean-aware control
Built Around the Dynamics
of a Leaning Vehicle.
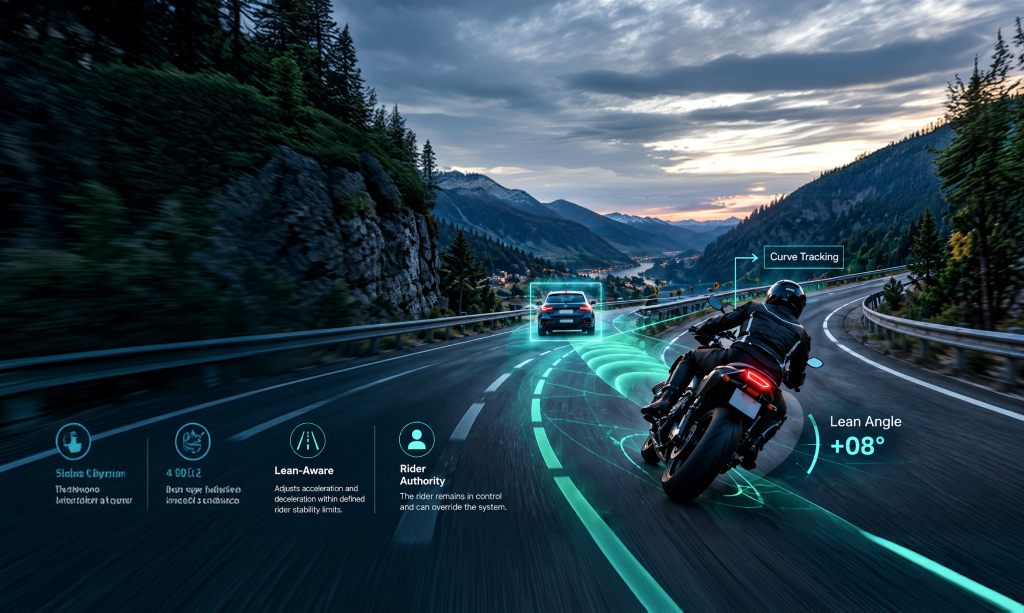
As the motorcycle leans through a curve, the perception and control system must account for vehicle roll while maintaining reliable target tracking.
-
Lean-Angle Awareness
Use IMU-derived vehicle state to understand motorcycle lean.
-
Target Association
Correct radar target association for roll angle.
-
Curve Tracking
Maintain reliable tracking as the motorcycle moves through curves.
-
Stability-Aware Control
Keep acceleration and deceleration within defined two-wheeler stability limits.
-
Rider Authority
The rider remains in control and can override the system.
Let’s Build Mission-Critical
Engineering Together.
Partner with SpeedEdge for mission-critical engineering, compliance and validation.